Robots
Every robot we have built
One robot per season since 2020. Click a card: it grows into the robot's page with subsystem tabs, callouts on the render, tradeoffs and iterations.
Robots
One robot per season since 2020. Click a card: it grows into the robot's page with subsystem tabs, callouts on the render, tradeoffs and iterations.
2025-26 · Decode
Four swerve pods, a three-artifact intake and a turreted flywheel that fires only at target RPM.
Four coaxial swerve pods give omnidirectional control with independent steering on every wheel.

An Axon Mini MK+ servo turns the pod through 270 degrees.
The drive motor turns the wheel through a bevel pair inside the pod.
One motor per wheel. Four motors and four servos in total.
Grip tape on the tread for traction. Plates and tensioners stop slip.
Drivetrain type
| Option | Traction | Pushing power | Maneuverability | Power draw | Motor count |
|---|---|---|---|---|---|
| Coaxial swerve Chosen Omnidirectional with independent steering. | strong | strong | strong | not stated | strong |
| Mecanum Low traction and low pushing power. | weak | weak | not stated | not stated | not stated |
| Six wheel Power draw, maneuverability and the motor limit of 8. | not stated | not stated | weak | weak | weak |
A surgical tubing roller feeds a single channel that holds exactly three artifacts.

Surgical tubing fingers pull artifacts into the channel.
Each motor drives through a bevel gear to keep the intake short.
One ball wide. Artifacts queue left to right.
Mounts to the frame so the module swaps without a rebuild.
Intake type
| Option | Fits the size limit | Holds three | Jam resistance |
|---|---|---|---|
| Surgical tubing roller Chosen Spans the front. Artifacts self-arrange. | strong | strong | strong |
| Drop-down roller Exceeded 18 x 18 in. Scrapped. | weak | not stated | not stated |
| Wheel intake Considered. | not stated | not stated | not stated |
| Rubber band intake Considered. | not stated | not stated | not stated |
A single flywheel on two belted 6000 RPM motors, a servo hood and a turret that rotates 270 degrees.
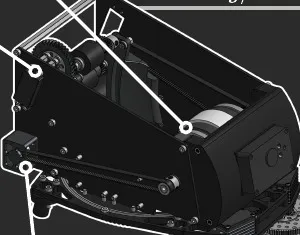
One wheel, two motors, one belt.
Metal disks keep the wheel speed up between the three shots.
Both 6000 RPM motors drive the flywheel through one belt.
A servo sets the release angle through herringbone gears.
Flywheel layout
| Option | Simplicity | Shot consistency |
|---|---|---|
| Single flywheel Chosen 90% consistent shots with inertial disks. | strong | strong |
| Dual flywheel Considered. | weak | not stated |
Staging
| Option | Simplicity | Shot consistency |
|---|---|---|
| Passive staging Chosen Artifacts queue on their own and fire in quick succession. | strong | strong |
| Active indexing Considered. | weak | not stated |
Auto-aim from odometry and Limelight AprilTags, a quadratic distance to RPM model and a state machine autonomous.

Tags 20 and 24 on the goal give the turret its offset.
Odometry aims first. The tag corrects the last few degrees.
Before Fixed release angle.
After A servo hood sets the angle for each shot.
Before Drop-down roller intake that exceeded 18 x 18 in.
After A simple roller that fits the size limit.
Before A slow spin-up ramp took 5 s.
After Inertial disks and aggressive PID bring it to 1.5 s.
Before A narrow intake.
After The intake spans the full front of the robot.
Before Earlier hood drive.
After Herringbone gears drive the hood.
Hardware
Outreach
Competition
Results
Santa Clara, California
Alliance captain
Folsom, California
Palo Alto High School, Palo Alto, California
Competed
